Result description
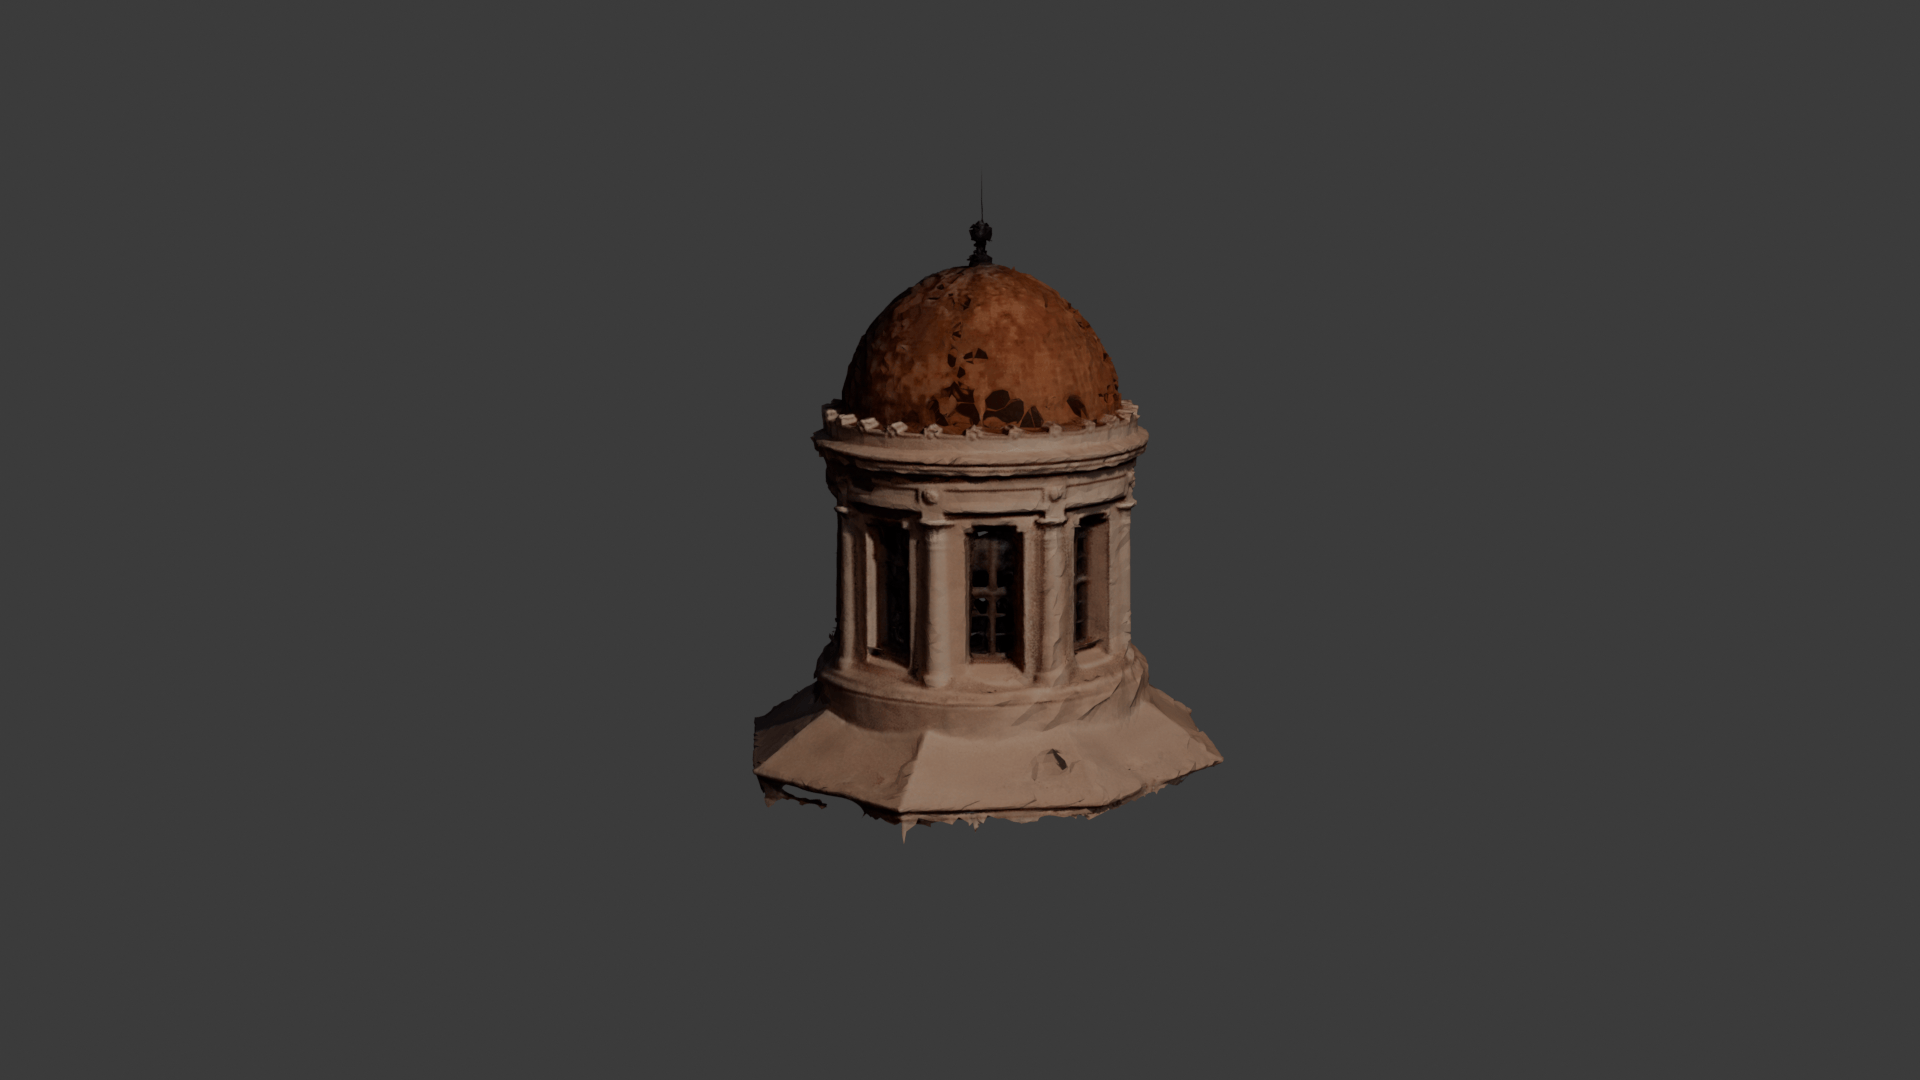
This innovation addresses a critical bottleneck in 3D scene reconstruction by enabling high-fidelity mesh extraction from Neural Radiance Fields (NeRFs). While NeRFs excel at photorealistic view synthesis, their implicit volumetric representation is incompatible with real-time graphics and simulation pipelines that require explicit polygonal meshes. The innovation introduces a Signed Distance Function (SDF) with spatially-varying sharpness control, a key advancement where the surface boundary sharpness parameter (beta) is learned through a neural network rather than fixed, enabling sharper and more accurate surface localization. The method combines grid-based NeRF initialization for geometry and appearance decomposition with differentiable mesh refinement, iteratively optimizing vertex positions and mesh resolution based on rendering errors. The result is a practical bridge between neural implicit fields and conventional mesh-based pipelines, enabling downstream applications in robotics, photogrammetry, extended reality, and physics simulations that depend on precise geometric representation.
Addressing target audiences and expressing needs
- Collaboration
Collaboration on improving further this technology.
- Research and Technology Organisations
- Academia/ Universities
R&D, Technology and Innovation aspects
Continue the research to further advance the technology in accuracy and rendering quality.
The published results are fully reproducible using the provided source code available at https://github.com/VCL3D/HAME-NeRF.