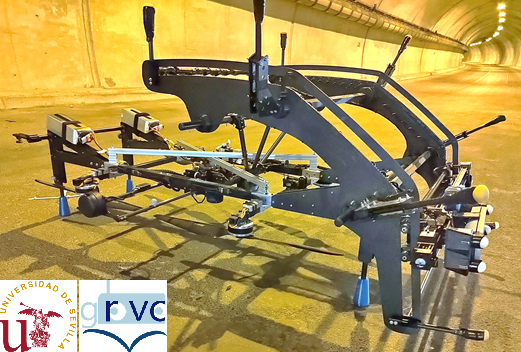
An aerial robot with a curved surface-sweeping 2D manipulator device able to fly inside tunnels, contact the tunnel walls at any angle and take measurements with the sensors mounted on the manipulator. The robot is based on a multirotor aerial platform. The manipulator device carries a cart where different sensors can be attached, as ultrasonic sensors for crack width, depth and Young’s modulus, a radiometric sensor for rebar detection, cameras for close inspection and measurement, etc. The cart is driven by two servomotors to sweep the area of interest. Another servomotor is used to adapt the manipulator device to the curved surface. A localization system designed for tunnels and the aerial robot navigation and control system are included in the robot.
 Adaptation to climate change
Addressing target audiences and expressing needs
- We are sharing our knowledge
- Others/ No specific audience
R&D, Technology and Innovation aspects
Prototype built and tested in real tunnel environment.
……………………………………………….
The unit cost can decline as the business expands..
.
.
.
.
.
.
.
……………………………………………….
It has been tested in different lab and real environments.
……………………………………………….
Prior results with aerial robots for contact inspection and manipulation.
……………………………………………….